


- Stock: In stock
- Product code: 920372000001458895
- Weight Brutto: 5.00kg

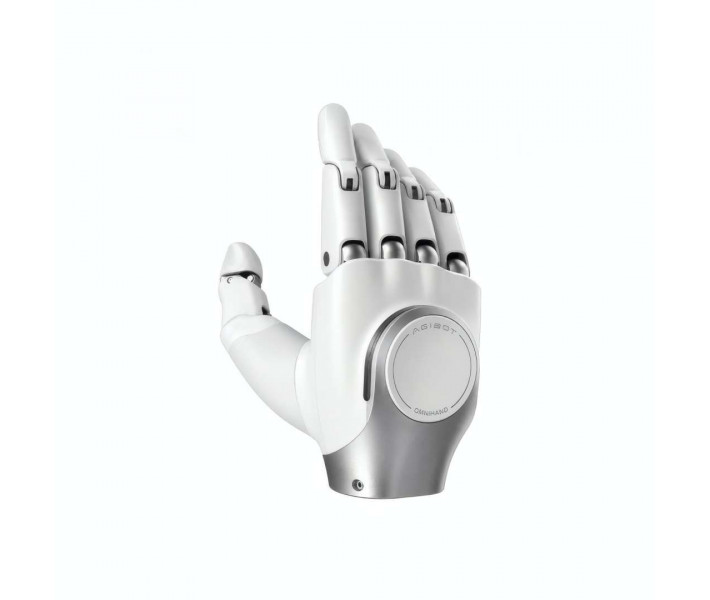
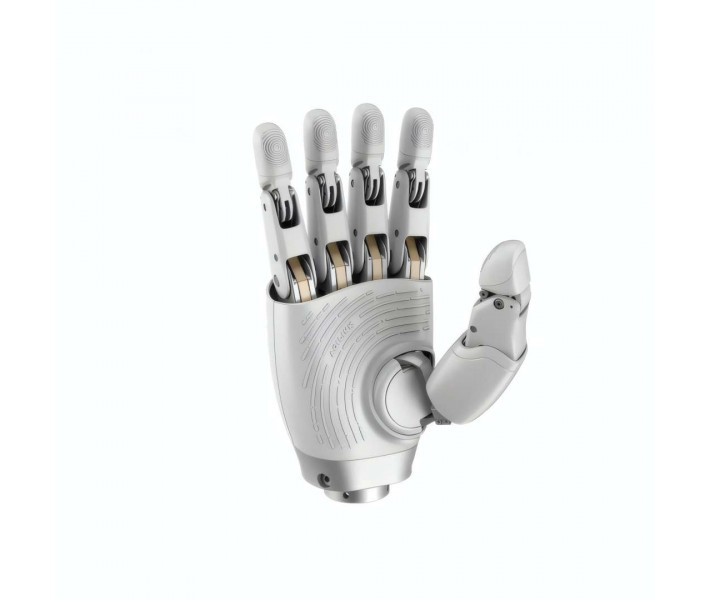
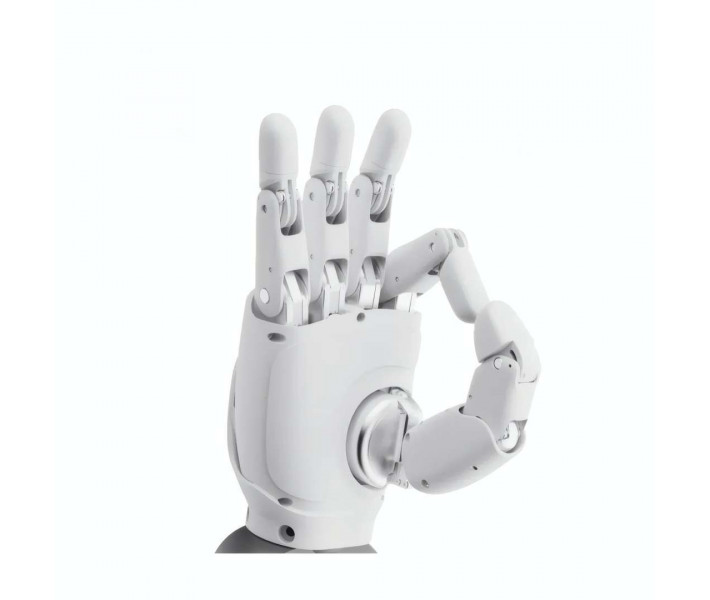
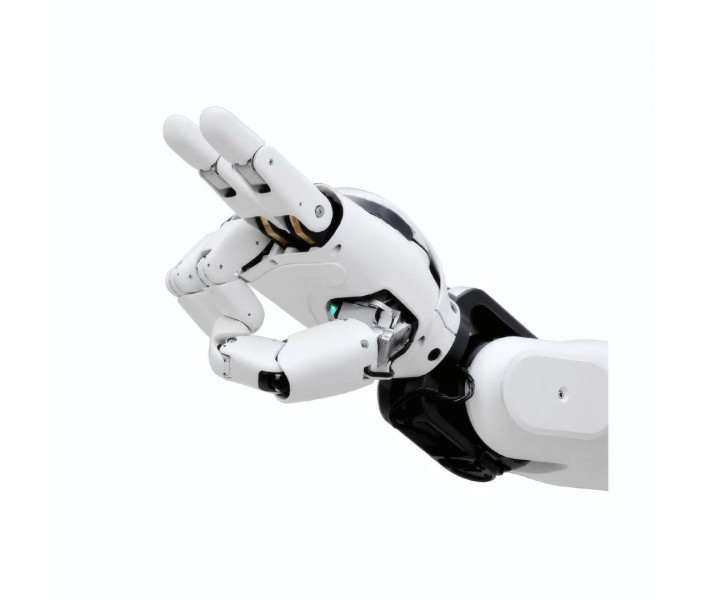
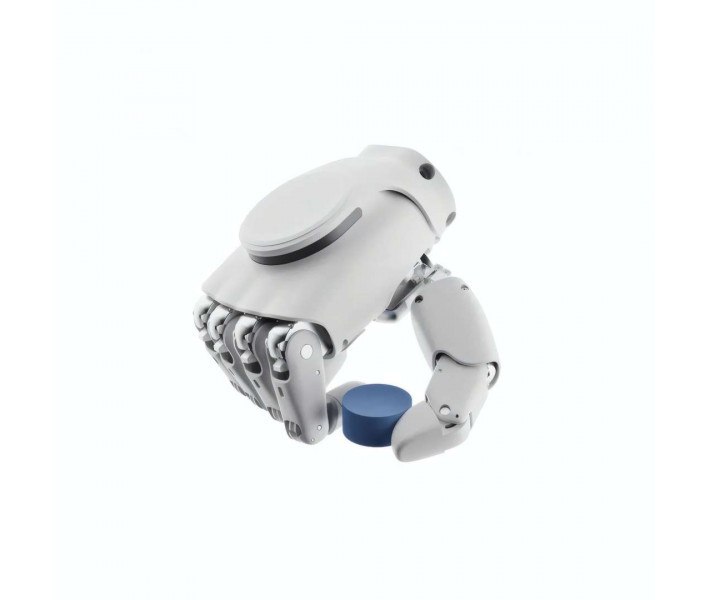
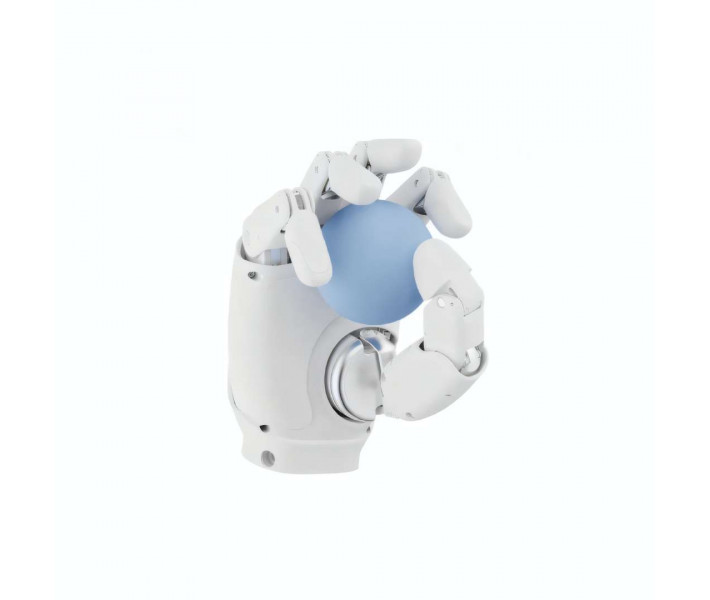
AgiBot OmniHand 3 — a dexterous robotic hand for humanoid platforms and mobile manipulators, designed for complex grasping tasks through biomimetic kinematics and continuous contact detection. Its ultralight structure preserves the dynamics of the carrier arm without limiting operational grip strength. It features surface sensitivity across the fingers and palm for handling objects with controlled precision.
Mechanical performance and operational advantages
- Load capacity: 5 kg — Holds heavy industrial parts and containers without compromising grip stability during dynamic transfers.
- Net weight: 510 g — Minimises the inertia of the end effector to avoid torque overload on the manipulator's wrists.
- Adaptive kinematics: 16 axes — Combines 10 active and 6 passive actuators to perform enveloping grasps on irregular geometries.
- Manoeuvre cycle: 0.5 s — Speeds up the full opening and closing phases in automated pick-and-place sequences.
- Integrated tactile array: Over 300 points — Enables precise surface monitoring with a resolution of 0.1 to calibrate force according to the fragility of each part.
- Perimeter sensing on the back of the hand — Registers unexpected contacts and lateral collisions to ensure collaboration in shared work areas.
- CAN FD and RS485 communication buses — Guarantee high-speed telemetry transfer with low latency and high resistance to electrical noise.
Mixed kinematics and motion control
The kinematic architecture of the end effector combines 10 active degrees of freedom with 6 passive ones. The independent actuators receive direct angular commands to set analytical postures or regulate the grip force of the phalanges. The six mechanically compliant joints act as a physical suspension system that absorbs impacts and follows the contours of the object being held.
This biomimetic arrangement replicates the coordinated movements of the biological hand for handling tools and everyday objects.
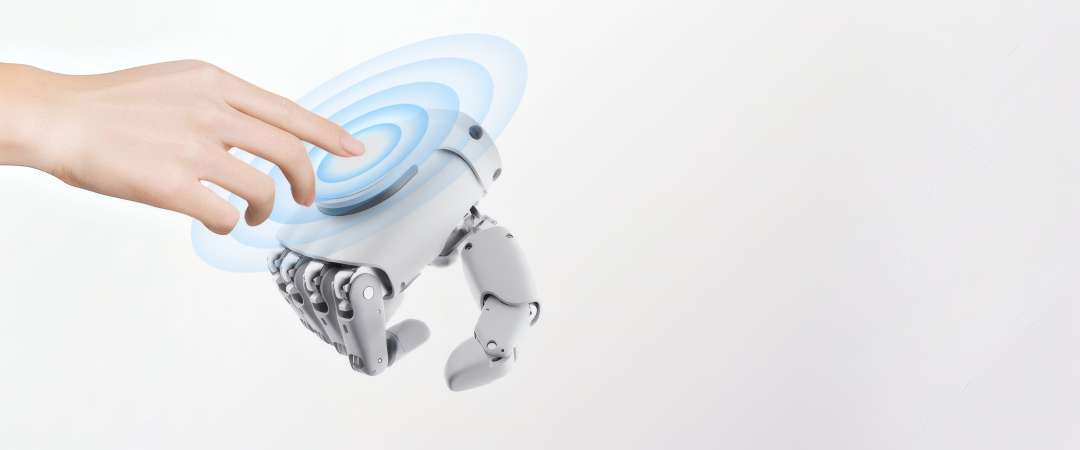
Haptic array and perimeter protection
The system features a sensor array exceeding 300 pressure points distributed across the fingertips, the palm and the outer back of the hand. Contact readings inform the controller in real time about load distribution with a resolution of 0.1. The integration of sensor cells on the back of the hand detects approaches and accidental contacts in collaborative environments.
The positioning repeatability of ±0.3 mm and the response of the sensors make it possible to handle fragile technical parts without slippage or damaging overpressure.
To protect technical personnel during testing and assembly, the joints between the fingers incorporate an anti-pinch physical design that eliminates cutting gaps during the rapid closing of the articulations.
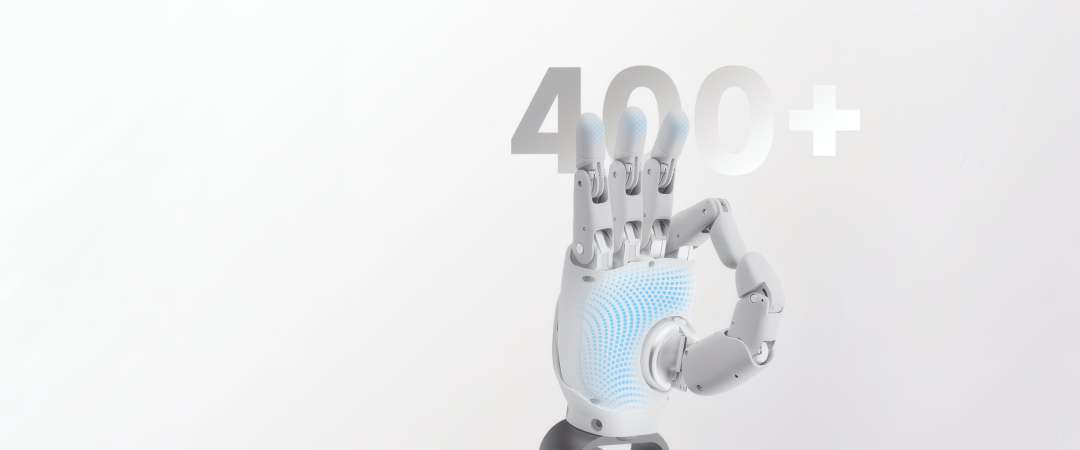
Load capacity and dynamic gripping
The internal transmission mechanism supports a handled mass of up to 5 kg through enveloping grasps. The distribution of stress among the fingers reduces wear on the gear trains when transporting bottles, tools or machined parts at high accelerations.
The 510 g structure allows the device to be installed on mobile robots without reducing the load capacity margin of the supporting arm.
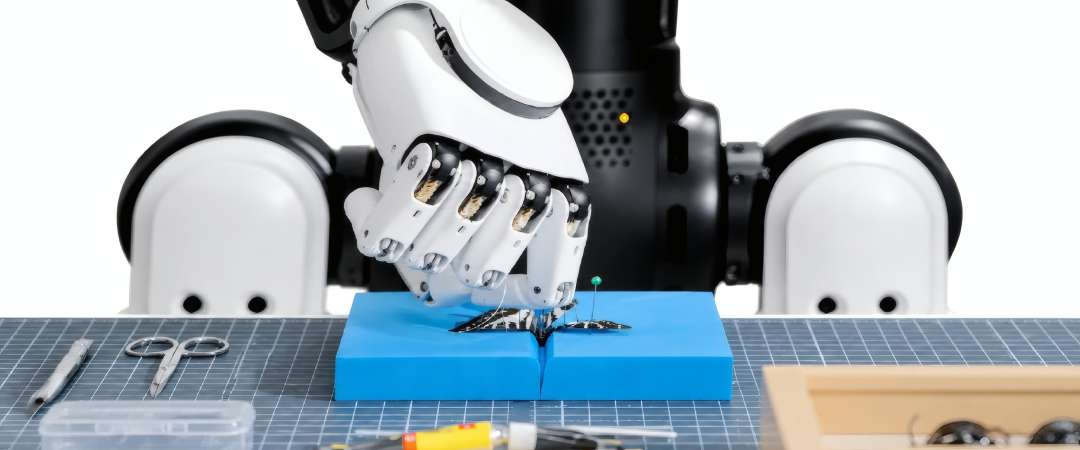
Control architecture and communication buses
The controller communicates via CAN FD differential buses and RS485 serial ports to ensure a constant refresh rate free from electromagnetic interference. The software environment offers native support for ROS 2 nodes, C++ libraries and Python scripts, as well as direct integration with the Dex-UMI teleoperation platform.
The following video shows the functional integration and the smoothness of motor control on test benches:
Additional mechanical tests demonstrate the response of the end effector to different geometries and holding forces:
Areas of application
- Research and development: experimentation with reinforcement learning models, tactile vision and inverse kinematics in academic environments.
- Humanoid robotics: incorporation of haptic gripping and natural gestures in robotic arms and bipedal humanoids.
- Mobile manipulation (AMR and AGV): transport of laboratory samples, opening of cabinets and component serving in internal logistics.
- Service and assistance robots: safe handover of everyday objects to people and execution of assisted household tasks.
- Teleoperation systems: real-time replication of human hand postures using capture devices or haptic interfaces.
Package contents
- OmniHand grasping module with actuators and sensor skin
- RS485 communication cable
- CAN FD communication line
- Main power harness
- USB Type-C data cable
- Certificate of approval and conformity
Technical specifications
Kinematics and performance
| Parameter | Value |
| Motion axes | 10 active + 6 passive |
| Total degrees of freedom | 16 |
| Maximum supported load | 5 kg |
| Full opening / closing time | 0.5 s |
| Positioning repeatability | ±0.3 mm |
Sensors and electronics
| Parameter | Value |
| Integrated tactile nodes | Over 300 points |
| Haptic sensor type | One-dimensional array (1D) |
| Sensor resolution | 0.1 |
| Data buses | CAN FD, RS485 |
Software and dimensions
| Parameter | Value |
| Development framework | ROS 2 |
| Programming support | Python, C++ |
| Supported remote control | Dex-UMI |
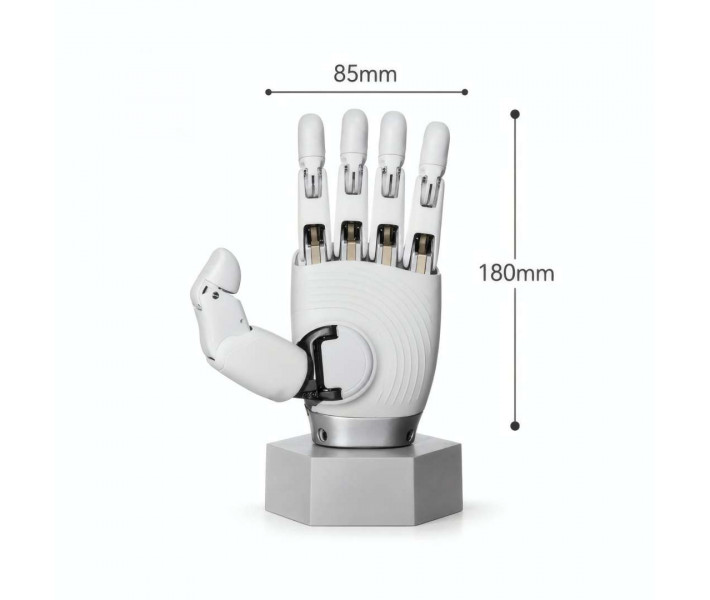
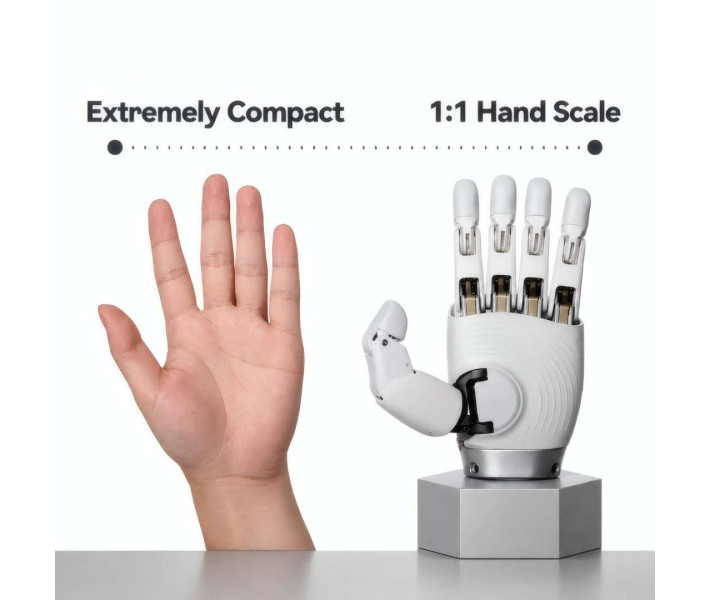
| External dimensions | 180 × 85 × 38.5 mm |
| Net weight | 510 g (0.510 kg) |
Why buy AgiBot OmniHand 3 at EXPERT3D?
EXPERT3D supplies professional robotics equipment and advanced technology. We provide personalised pre-sales advice to adapt the mounting brackets to your robot's wrist. We offer direct after-sales support for integration into ROS 2 and C++ or Python development environments. We handle the safe delivery of your equipment. We keep consumables, connection accessories and spare components permanently in stock.



















































