

- Stock: In stock
- Product code: 920372000001458180
- Weight Brutto: 98.00kg

AgiBot X2 is a humanoid robot for dialogue and autonomous tasks without remote control. The operator does not need to guide the robot step by step or correct its route manually. Navigation and proactive obstacle avoidance are handled by a decision-making algorithm. Multi-joint kinematics reproduces a human gait, while multimodal interaction supports dialogue.
Key features and benefits
- Degrees of freedom: 25 — The arm, waist and leg joints reproduce walking, two-handed gestures and torso tilts.
- Walking speed: up to 1.8 m/s — The typical operating value is lower than the maximum, so factor it into route calculations.
- Runtime: approx. 2 hours (walking at 0.5 m/s) — A swappable battery means you do not have to wait for charging to finish.
- Multimodal interaction: the visual and voice channels are complemented by a tactile one, so the dialogue takes into account the user's gestures and the context of the conversation.
- Autonomous navigation: the decision-making algorithm guides the robot and avoids obstacles, so the operator does not control every step.
- OTA updates: the software is updated wirelessly, so no physical connection is needed for a new version.
AgiBot X2 multimodal interaction
The AgiBot X2's multimodal interaction is provided by four channels, each with its own hardware module. The robot integrates the user's gestures and the conversation context with environmental data. As a result, the dialogue remains natural across different usage scenarios.
- Visual channel: an interactive RGB camera recognises the user's face and gestures.
- Voice channel: a microphone array picks up speech, and the speaker plays the robot's replies.
- Tactile channel: a touch sensor is mounted on the head and registers touches.
- Facial expressions: an interactive display and light effects complement the response visually.
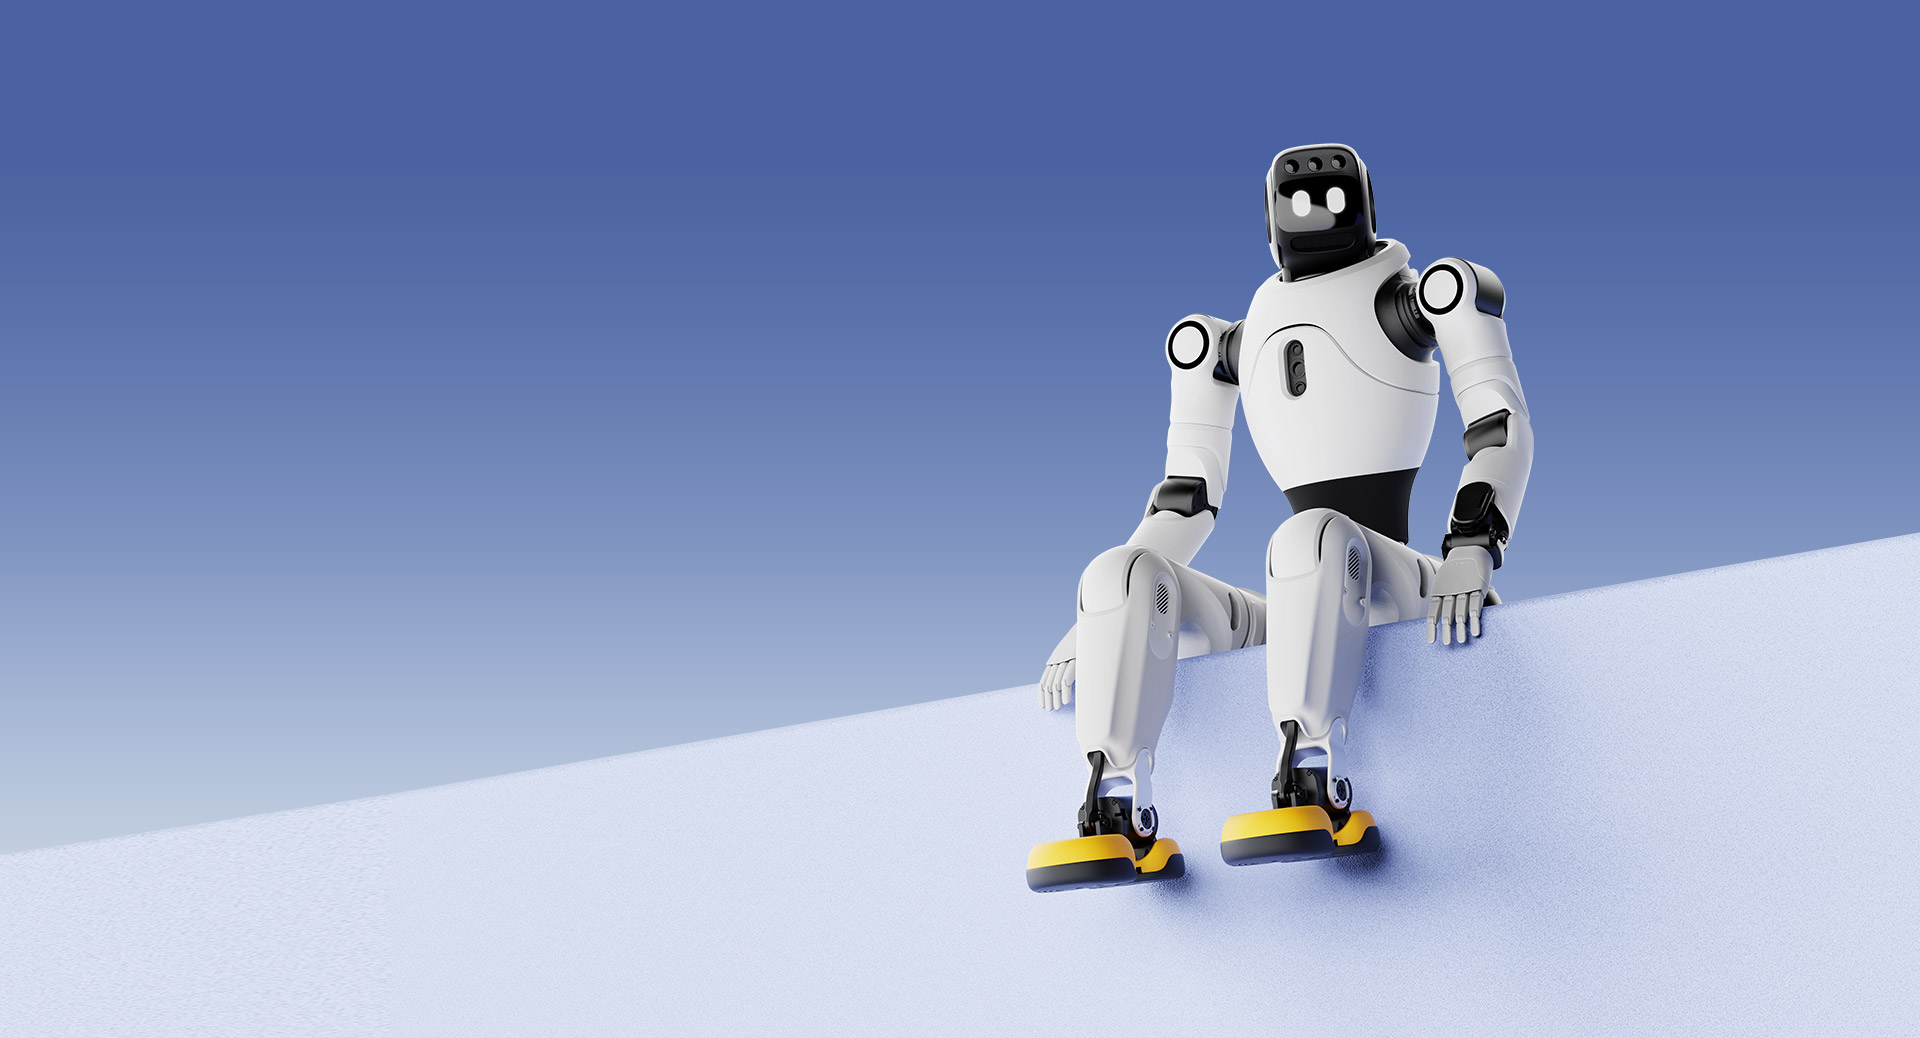
The platform is approx. 1.31 m tall and weighs approx. 35 kg. The humanoid body is visible in the image, where the robot sits on a raised ledge against a blue background.
Mobility and human-like gait
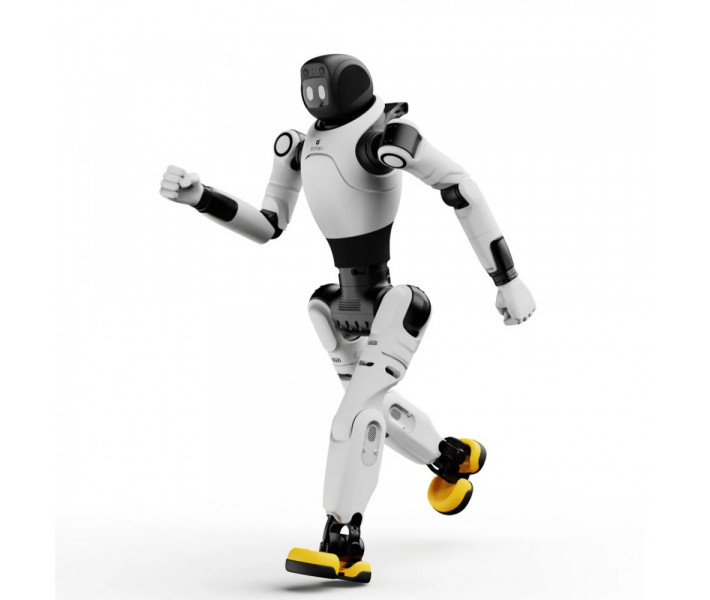
This robot supports a human-like gait and complex dance routines. The maximum walking speed reaches 1.8 m/s, while the typical speed does not exceed 0.8 m/s. In a laboratory environment, a value of no more than 2 m/s is stated.
The video "When football meets humanoid robots" adds context to the topic of human-like movement. It complements the description of the gait and motion programmes.
Autonomous tasks without remote control
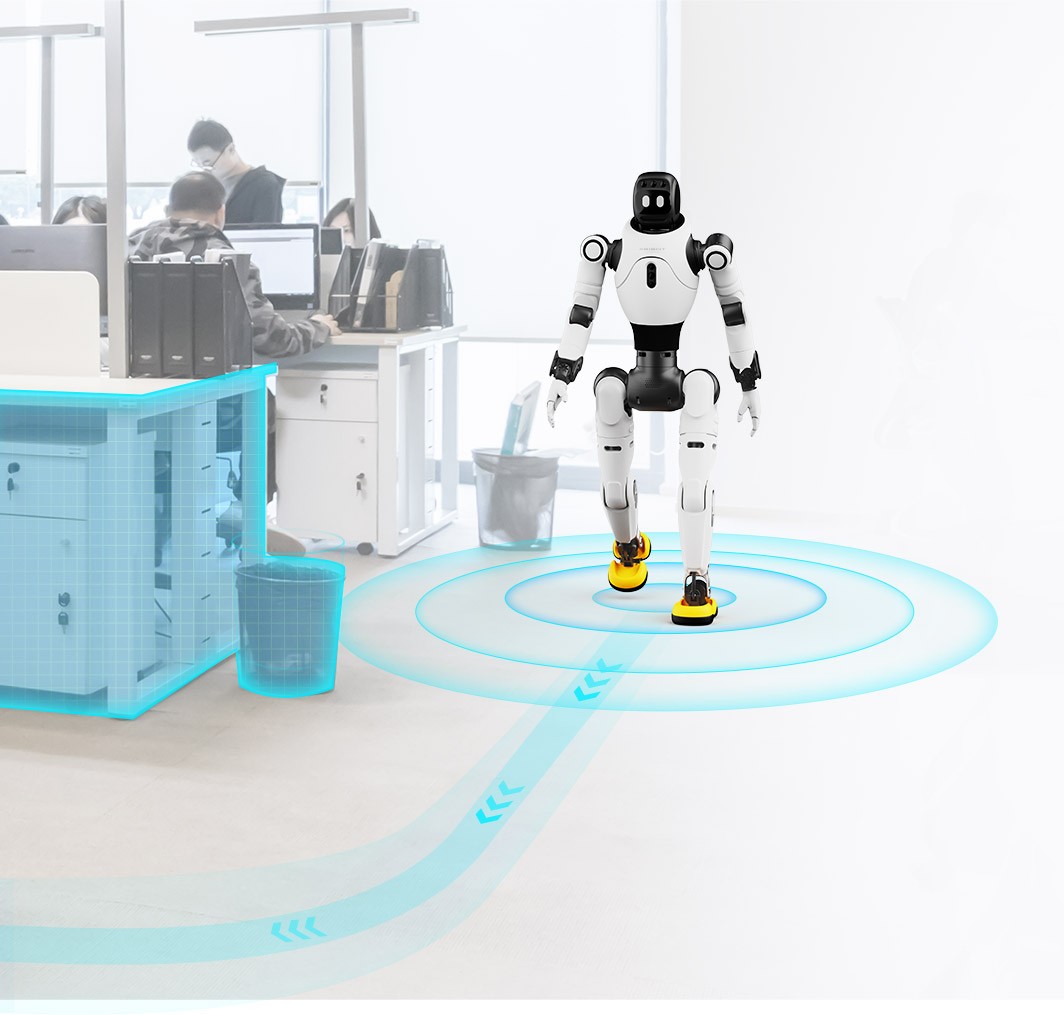
Autonomous navigation and proactive obstacle avoidance in the AgiBot X2 are provided by a decision-making algorithm. Therefore, remote control is not needed for operation.
Computation is handled by two main RK3588 boards. There is no separate high-performance board in this configuration. Path planning and obstacle avoidance in an office environment are shown in the image.
Bionic body and degrees of freedom
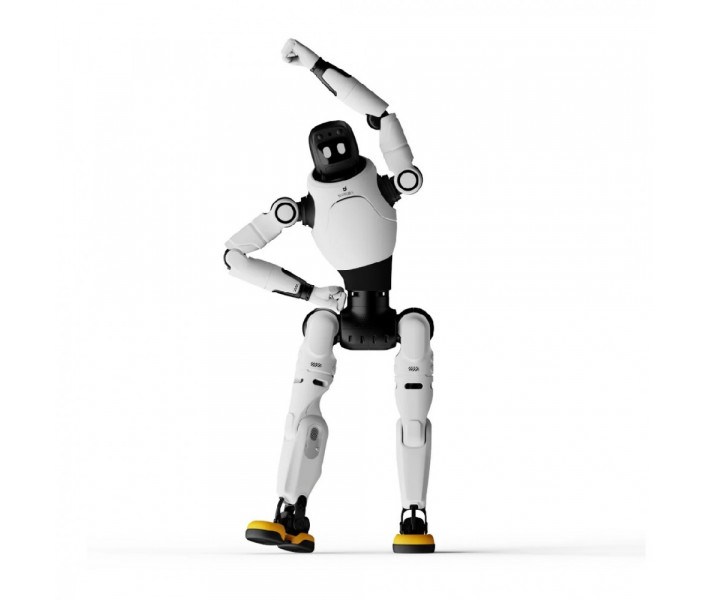
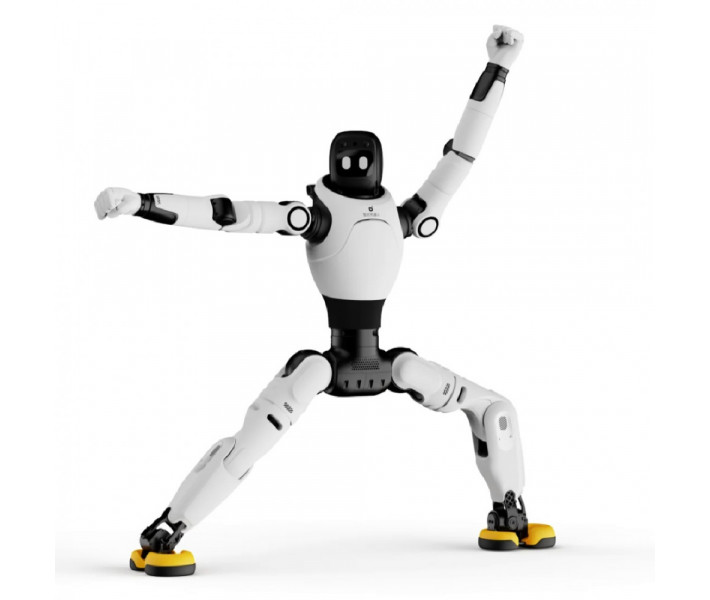
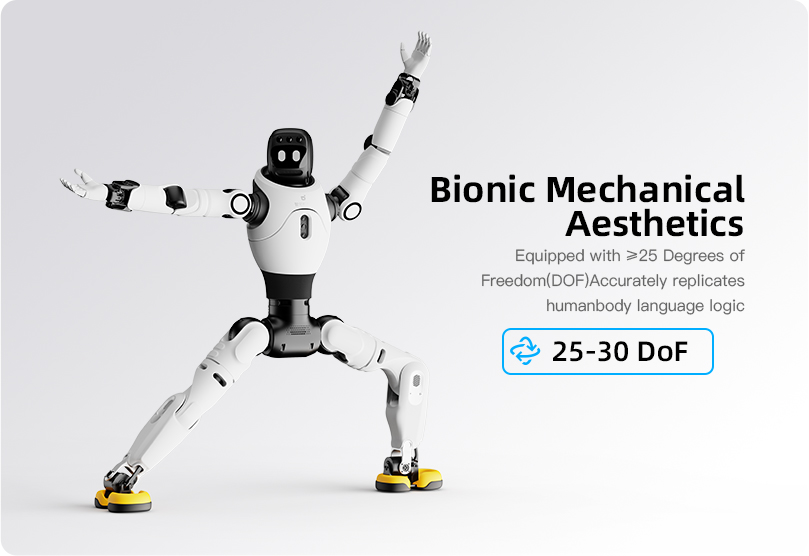
The robot has 25 degrees of freedom (DoF — independent joint motion axes). This number of axes reproduces the logic of human body language. The distribution of axes by unit is given below. A sporty pose showing the flexibility of the body is shown in the image.
Arms
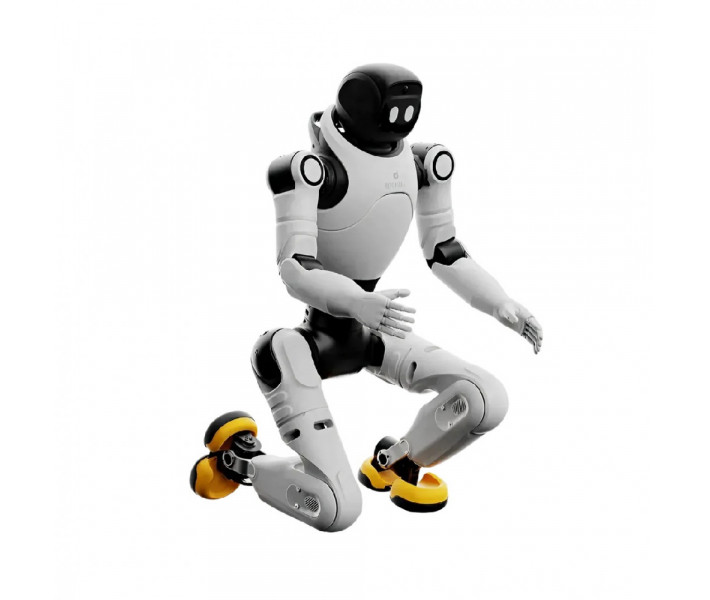
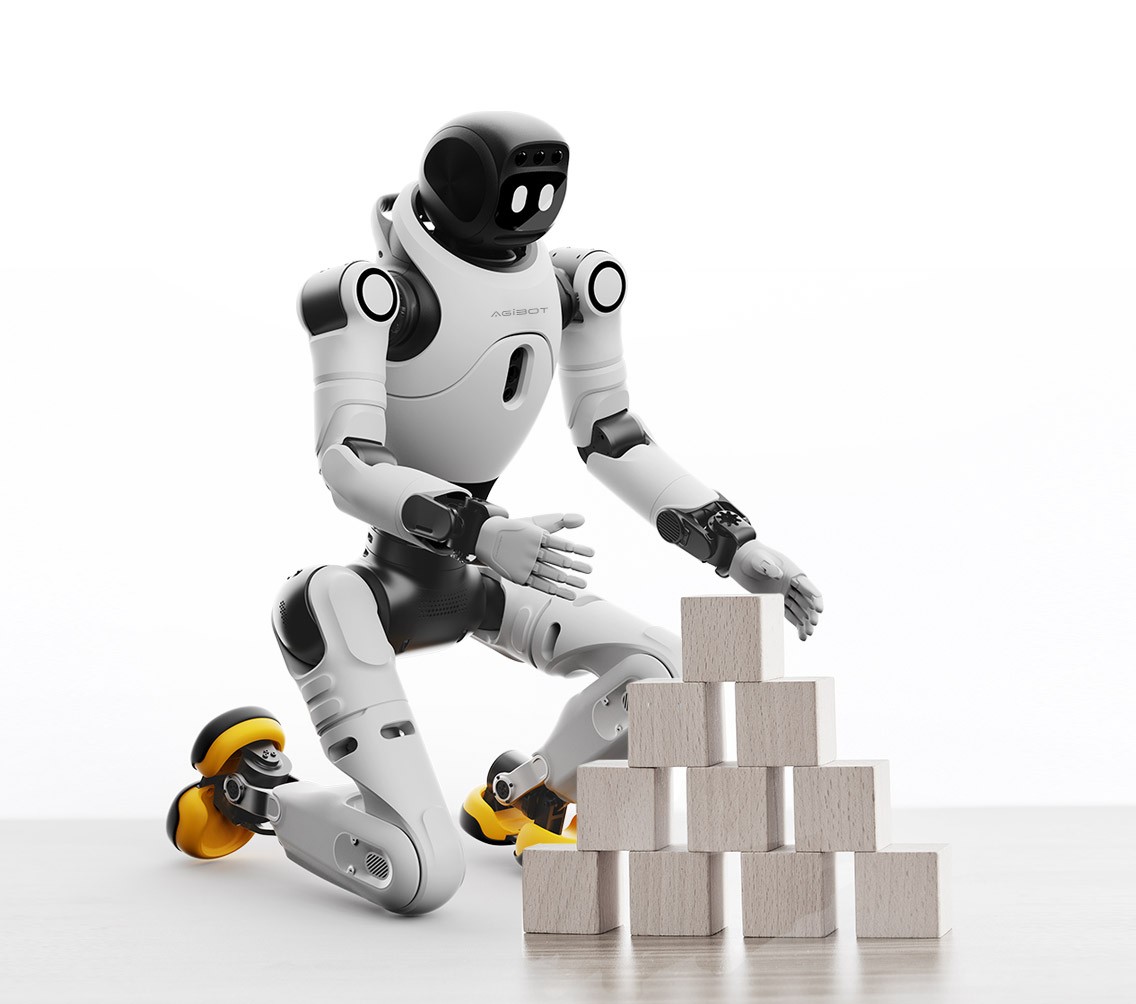
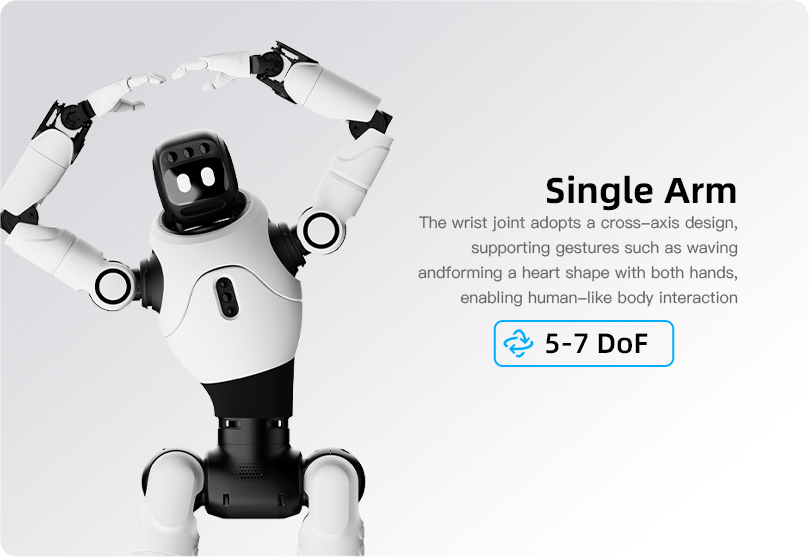
Each arm has 5 degrees of freedom. The arm reach is 558 mm. The payload is up to 3 kg in certain positions. Across the full range of motion it does not exceed 1 kg. The reach and both payload values are given excluding the end effector. Handling objects is shown in the image: the robot kneels, stacking a pyramid of wooden blocks.
The wrist joint is built with a cross-axis layout. This makes it possible to wave a hand and form a heart shape with both hands. The mobility of the arms and the gestures are visible in the image, where the arms are bent above the head.
Waist
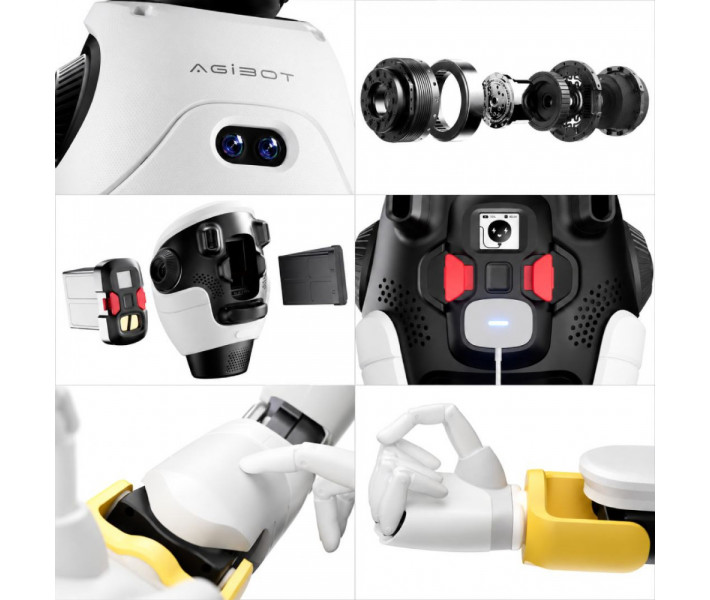
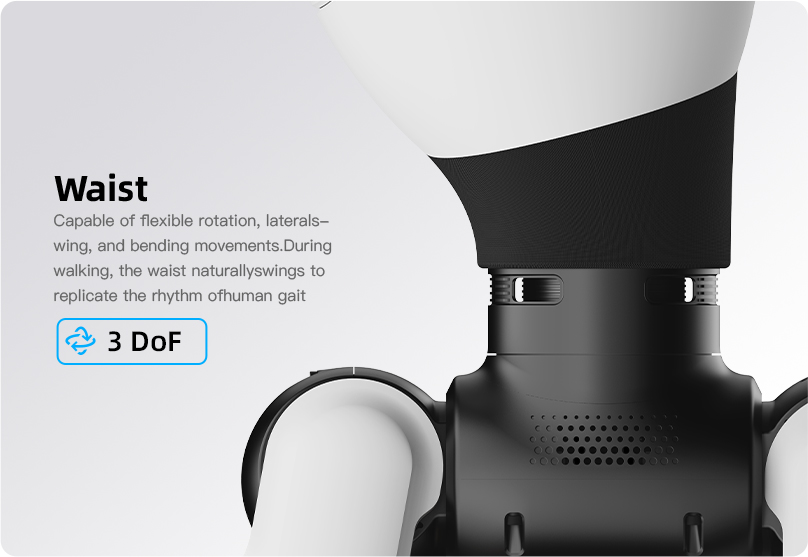
The waist has 3 degrees of freedom. It performs flexible rotation, side tilts and bending. While walking, the waist sways naturally, reproducing the rhythm of a human gait. The waist joint, which is responsible for rotating and bending the torso, is shown in the image.
Legs
Each leg has 6 degrees of freedom. The peak joint torque is 120 N·m. This is the upper limit of the dynamic load on the joints during walking.
Head
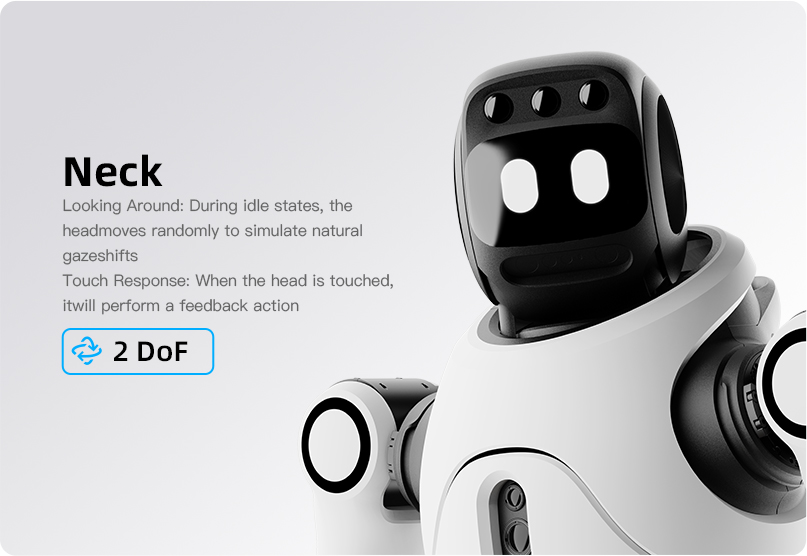
At rest, the robot imitates natural changes of gaze. A touch on the head is registered by the touch sensor, and the robot performs a feedback action. The head module with a digital eye display is shown in the image.
Sensors and environmental perception
The interactive RGB camera recognises faces and gestures. It also detects objects and builds a semantic perception of the environment.
In this configuration, a 3D LiDAR and an RGB-D camera are not installed. Both modules are included as standard in the AgiBot X2 Ultra version. The RGB-D camera provides spatial perception with depth data. A multi-line LiDAR collects a point cloud for high-precision positioning in 3D SLAM (simultaneous localisation and mapping).
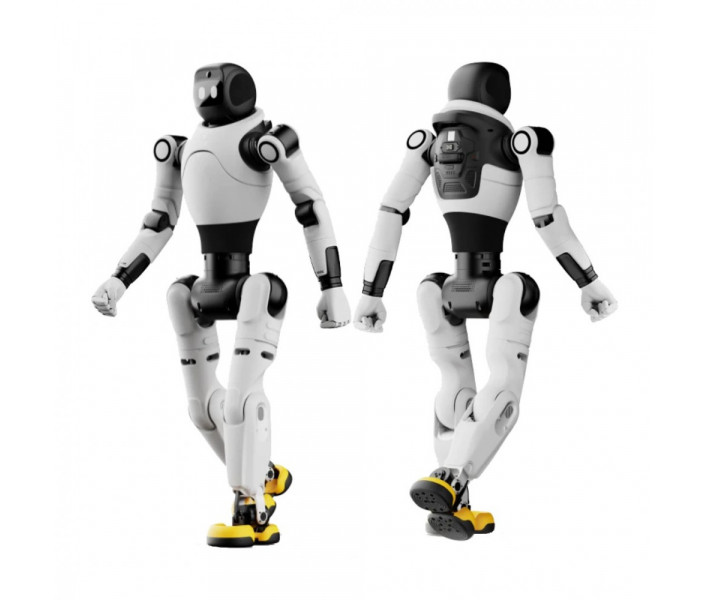
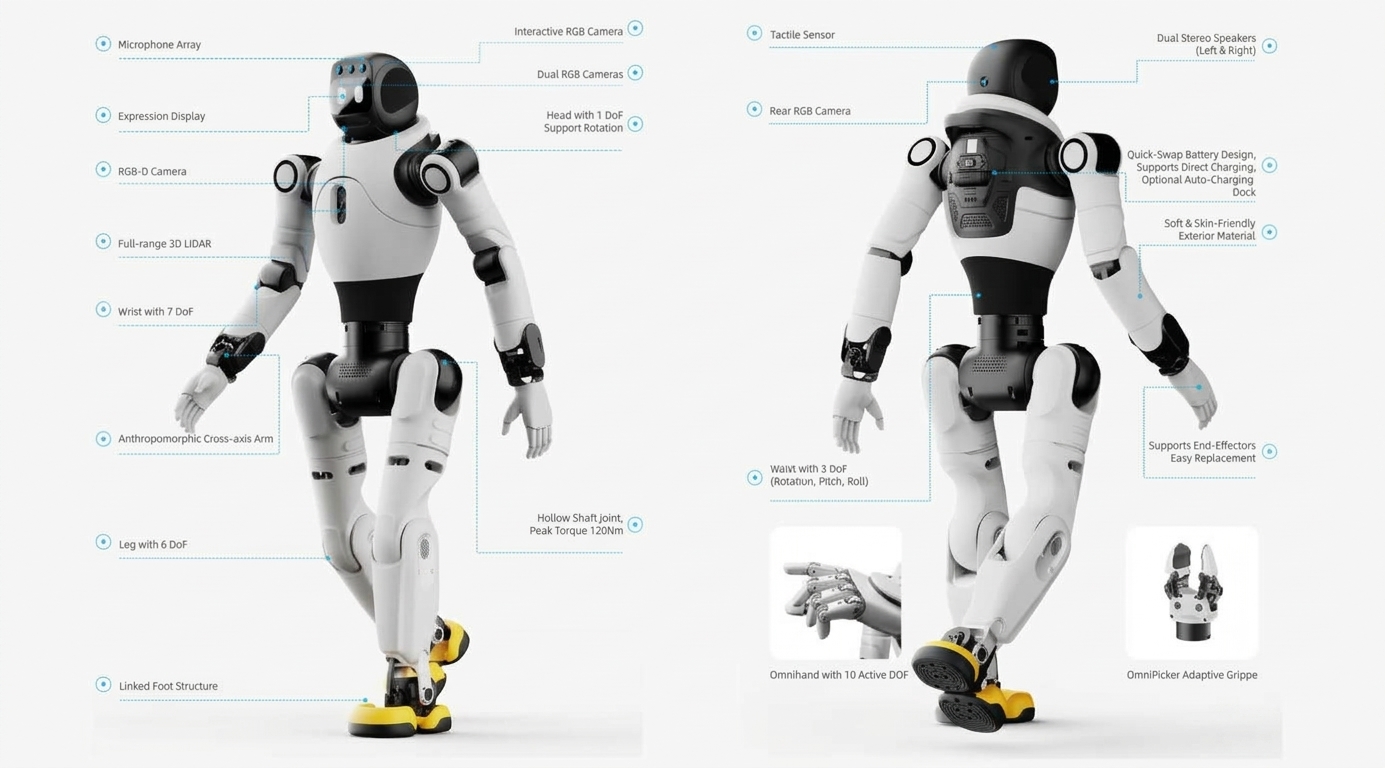
Of the perception sensors, an interactive RGB camera and a touch sensor on the head are installed. The layout of the sensors and joints is shown in the diagram of the robot from the front and back.
Power and charging
The battery capacity is approx. 500 Wh. The power options are direct charging or battery replacement.
Charging takes no more than 1.5 h. The charger input voltage is 100 to 220 V. The output is 54.6 V, 10 A.
Software, connectivity and interfaces
The robot supports connectivity via Wi-Fi and Bluetooth. OTA updates (wireless software updates) and a mobile app are supported. Secondary development is not supported, so take this into account at the project planning stage.
For hardware expansion, one USB Type-A port and one USB Type-C port are provided. The power outputs are one 12 V/3 A and one 48 V/5 A. There are no LAN ports. A handheld controller is available as an option.
Applications
- Multimodal dialogue: the AgiBot X2 picks up speech with a microphone array and recognises faces and gestures with an RGB camera. It delivers its response through the speaker, display and light effects.
- Demonstration programmes: dance routines and two-handed gestures, such as waving or a heart shape, rely on 25 degrees of freedom. A wrist joint with a cross-axis layout enables two-handed gestures.
- Autonomous indoor movement: in an office environment, the robot plans its path and avoids obstacles without remote control. Computation is handled by two main RK3588 boards.
- Handling light objects: arms with a reach of 558 mm have a payload of up to 3 kg in certain positions and up to 1 kg across the full range (without an end effector). This range suits small object-handling tasks, such as stacking a pyramid of blocks.
What's in the box?
- Robot — 1 pc.
- Charger — 1 pc.
- Microphone — 1 pc.
- Quick start guide — 1 pc.
- Certificate of conformity — 1 pc.
Technical specifications
General information
| Parameter | Value |
| Connectivity | Wi-Fi, Bluetooth |
| Audio input/output | Microphone array, wireless microphone, speaker |
| Display | Interactive screen, light effects |
| Main computing board | RK3588 ×2 |
| High-performance board | Not fitted |
Dimensions and operating conditions
| Parameter | Value |
| Dimensions | 1310 mm (H) × 460 mm (W) × 210 mm (D) |
| Height | Approx. 1.31 m |
| Weight | Approx. 35 kg |
| Operating temperature | From -10 °C to 40 °C |
Degrees of freedom and arm reach
| Parameter | Value |
| Total degrees of freedom | 25 |
| Neck degrees of freedom | 0 |
| Arm degrees of freedom (per arm) | 5 |
| Torso degrees of freedom | 3 |
| Leg degrees of freedom (per leg) | 6 |
| Arm reach | 558 mm, excluding the end effector |
Perception system
| Parameter | Value |
| 3D LiDAR | Not fitted |
| RGB-D camera | Not fitted |
| RGB camera | Interactive RGB camera |
| Head touch sensor | Fitted |
Performance
| Parameter | Value |
| Peak joint torque | 120 N·m |
| Walking speed | Up to: 1.8 m/s, typical: ≤0.8 m/s, laboratory environment: ≤2 m/s |
| Payload | Max. (in certain positions): 3 kg, across the full range: ≤1 kg, excluding the end effector |
Power system
| Parameter | Value |
| Battery capacity | Approx. 500 Wh |
| Runtime | When walking at 0.5 m/s, approx. 2 hours |
| Power method | Direct charging, swappable battery |
| Charging time | ≤1.5 h |
| Input voltage | 100~220 V |
| Charger output | 54.6 V, 10 A |
Hardware expansion interfaces
| Parameter | Value |
| USB ports | Type-A ×1, Type-C ×1 |
| LAN ports | Not fitted |
| Power output | 12 V/3 A ×1, 48 V/5 A ×1 |
Other
| Parameter | Value |
| Handheld controller | Optional |
| OTA updates | Supported |
| Mobile app | Supported |
| Secondary development | Not supported |
Why buy the AgiBot X2 from EXPERT3D?
EXPERT3D has been supplying professional 3D equipment since 2012. Our specialists advise you before purchase and help you choose an AgiBot X2 configuration. We deliver throughout Spain and the EU countries. After purchase, we provide service support for your equipment. Spare parts and consumables can be ordered on the website so that your equipment does not stand idle. Leave a request on the website, and we will prepare recommendations on the configuration.