

- Stock: In stock
- Product code: 920372000001458916
- Weight Brutto: 3.00kg

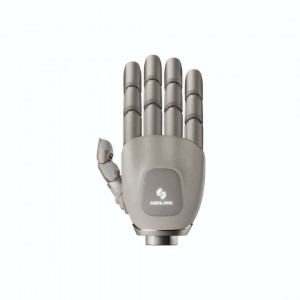
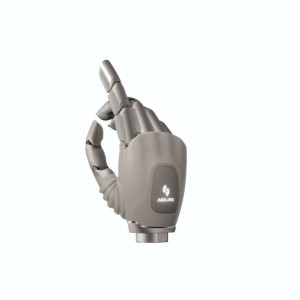
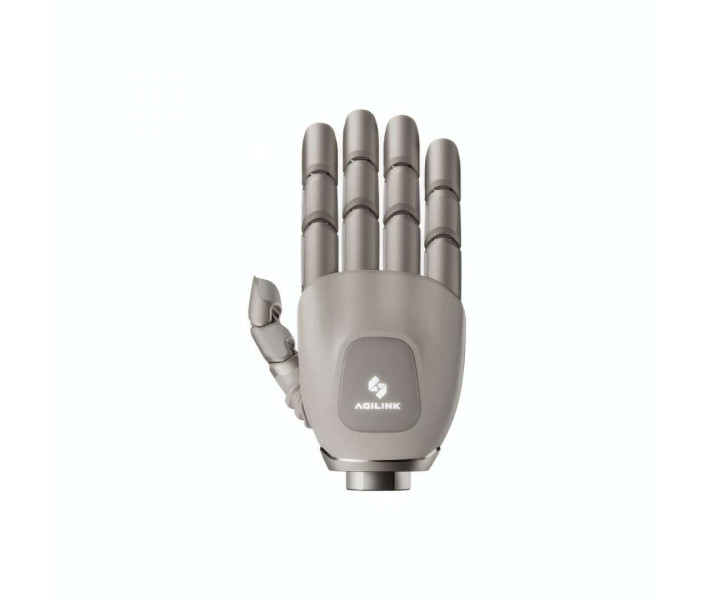
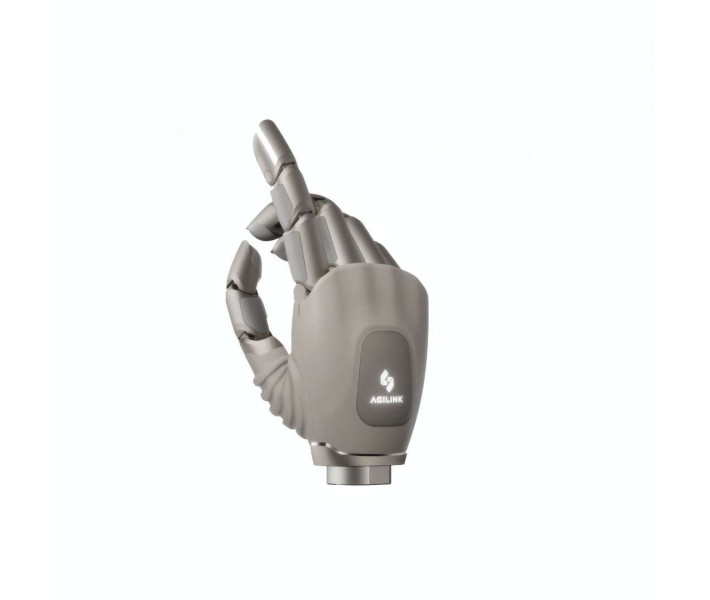
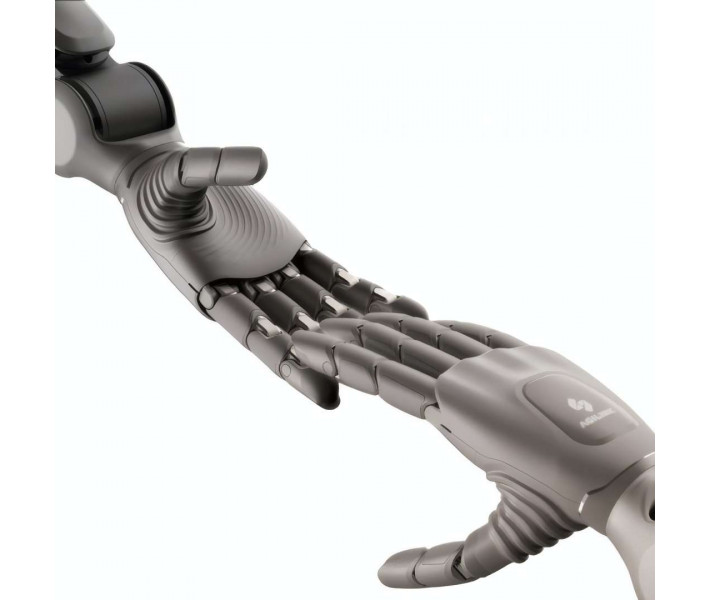
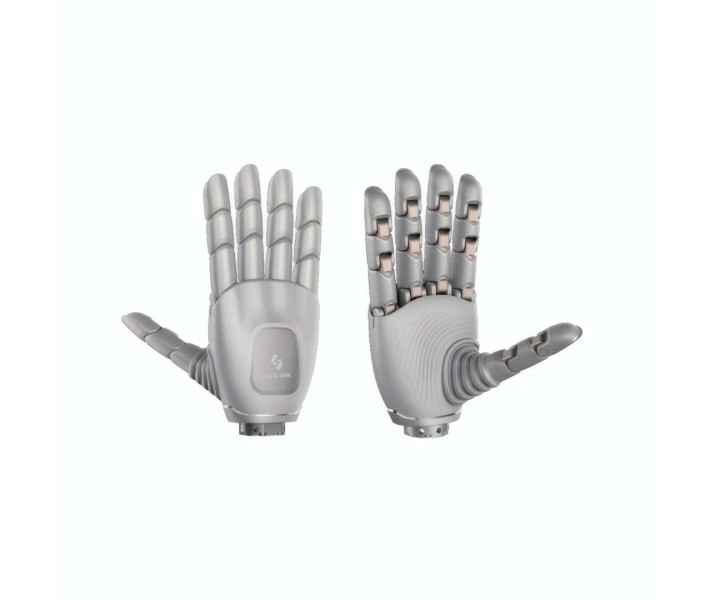
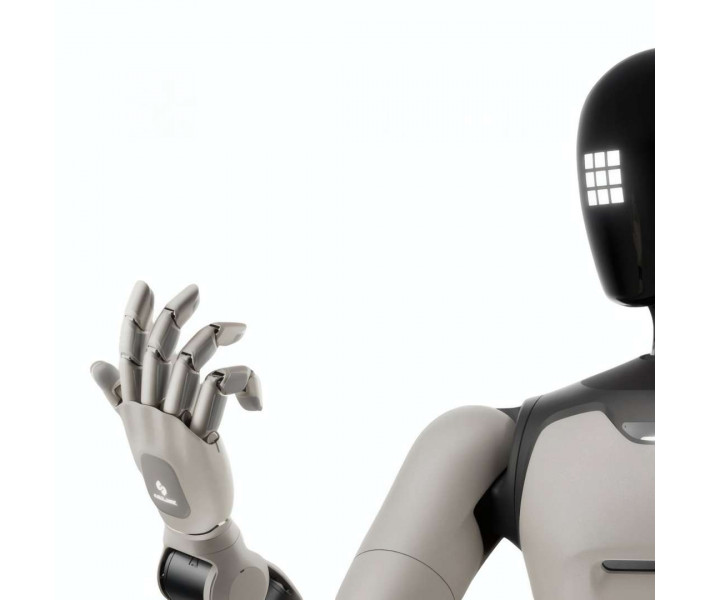
AgiBot OmniHand 3 Ultra-M — dexterous robotic hand for physical AI research and advanced humanoid platforms. The end effector replicates human kinematics through independent direct drive on every movable joint. It integrates optical tactile sensors and palm arrays to record precise bimanual contact data.
Key specifications and advantages
- Active degrees of freedom: 21 DoF — Enables enveloping grasps and fine pinch grips with full kinematic autonomy.
- Payload capacity: 5 kg — Supports heavy working tools without compromising the dynamics of the robotic arm.
- Positional repeatability: ±0.2 mm — Ensures precise dynamic trajectories in complex assembly tasks.
- Cycle time: 0.3 s — Delivers agile opening and closing to speed up continuous operating sequences.
- Pulley-free direct drive: transmits torque directly to the joint axis to eliminate backlash and speed up Sim2Real transfer.
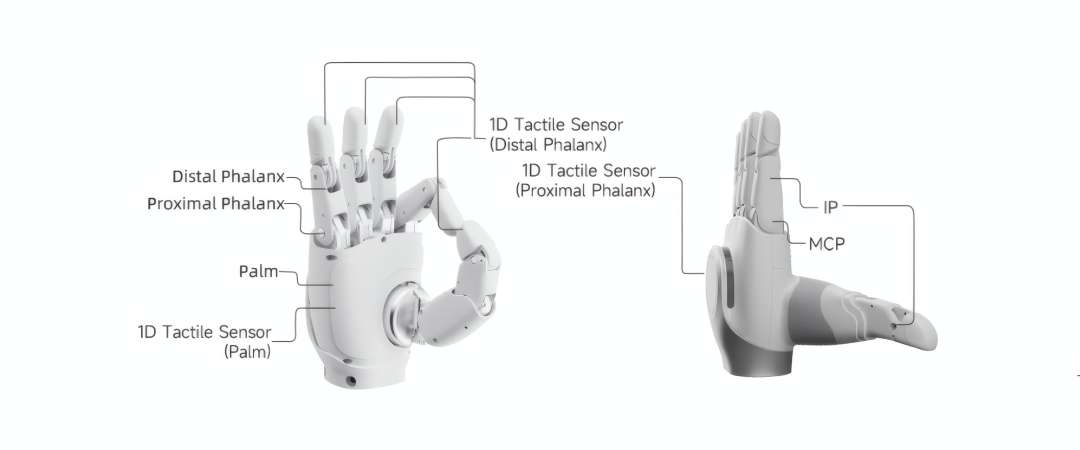
- Multidimensional tactile sensing: quantifies millimetre-scale deformations and force vectors of up to 30 N to prevent unwanted slippage.
Advanced kinematics and control in AgiBot OmniHand 3 Ultra-M
The robotic hand eliminates intermediate transmissions prone to backlash by using dedicated motors in every movable joint. This direct drive reduces mechanical play and ensures an immediate response in reinforcement learning control tasks.
The integration of absolute encoders in every link makes it possible to monitor angular position in real time with a constant repeatability of ±0.2 mm. The design withstands more than 500,000 working cycles while maintaining a stable operating temperature of between 40 and 45 °C.
Tactile sensitivity and fine motor dexterity
The fingertips house optical sensors that register surface variations from 0.08 mm of deformation. This architecture measures three-dimensional force vectors between 0 and 30 N with a minimum sensitivity of 0.005 N.
The motor control executes movements with short response times to handle fragile items without applying excessive pressure. This tactile capability optimises data capture during direct human demonstrations.
Palm array and mechanical load distribution
The palm surface incorporates an array of 300 independent points designed for readings with a resolution of 0.1 N. This arrangement calculates the pressure distribution when the manipulator carries tools with an extended support.
The compact chassis measures 189.5 × 88.5 × 40 mm and weighs 630 g, replicating the anthropomorphic scale of an adult hand. Its structural capacity supports a payload of up to 5 kg without altering the angular accelerations of the manipulator.
Connectivity and low-latency telemetry
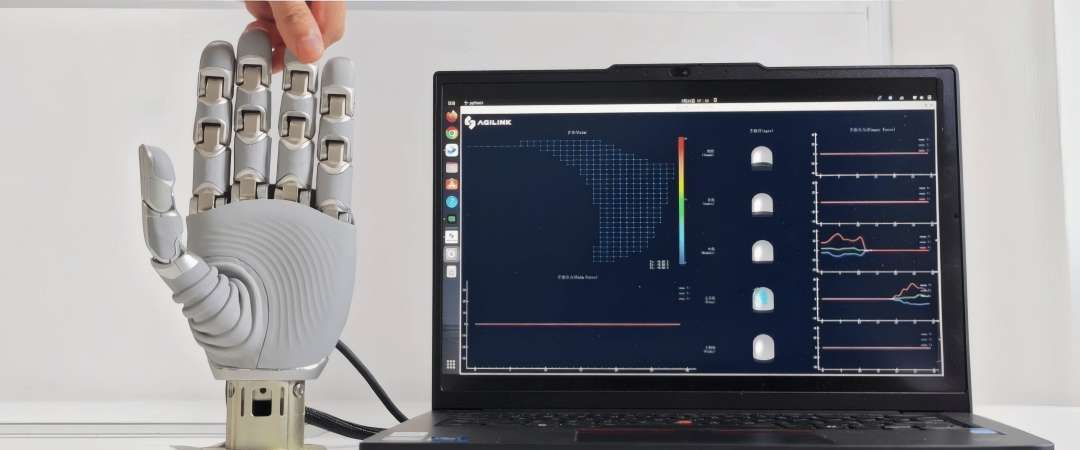
The system channels kinematic and sensory information through the CAN FD and Ethernet industrial communication protocols. This standardised interface facilitates integration into control nodes within ROS-based architectures.
Test bench trials validate continuous telemetry transmission during intensive bimanual operations. Real-time synchronisation simplifies the development of autonomous policies in physical experimentation environments.
Areas of application
- Physical AI training: generates continuous datasets for advanced imitation and reinforcement learning models.
- Coordinated bimanual manipulation: facilitates cooperative assembly and the safe handover of objects between robotic arms.
- Teleoperation and motion capture: transfers movements from haptic gloves to the mechanical end effector with low latency.
- Laboratory operations: holds pipettes, test tubes and analytical tools without the risk of breakage from excessive pressure.
- Precision technical assembly: inserts mechanical components and electronic connectors with real-time tactile guidance.
Compatibility and accessories
- AGIBOT A3 series: native integration optimised for direct bimanual tasks without intermediate adapters.
- AGIBOT A2 and G2 platforms: mechanical and electronic compatibility through adjustment of specific mounts.
- AGIBOT X2 family: functional adaptation of buses and fixings according to the requirements of the platform.
Technical specifications
Kinematics and mechanical performance
| Parameter | Value |
| Active degrees of freedom (DoF) | 21 |
| Drive type | Direct drive (Direct Drive) |
| Maximum payload | 5 kg |
| Cycle time (opening / closing) | 0.3 s |
| Positioning repeatability | ±0.2 mm |
Tactile sensors and perception
| Parameter | Value |
| Palm tactile sensor | Three-dimensional 3D array |
| Palm sensing points | 300 points |
| Palm force resolution | 0.1 N |
| Fingertip sensors | Optical tactile systems |
| Measurement range per finger | 0 – 30 N |
| Finger force resolution | 0.005 N |
| Tactile spatial resolution | 0.04 mm |
| Deformation detection accuracy | 0.08 mm |
Dimensions and connectivity
| Parameter | Value |
| Communication buses | CAN FD, Ethernet |
| External dimensions | 189.5 × 88.5 × 40 mm |
| Net weight | 630 g |
Why buy AgiBot OmniHand 3 Ultra-M at EXPERT3D?
EXPERT3D supplies professional advanced-technology equipment for robotics and applied research. We offer specialised technical advice to assess the feasibility of mounting on your robotic platforms. We manage the supply with an official warranty and dedicated after-sales support. We guarantee delivery of equipment throughout Spain and the European Union. We stock spare parts and offer direct technical support channels to keep your projects running continuously.