

- Stock: In stock
- Product code: 920372000001458937
- Weight Brutto: 3.00kg

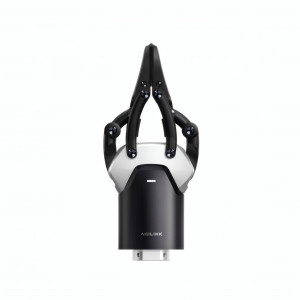
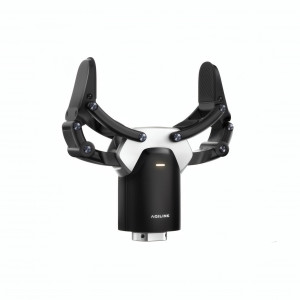
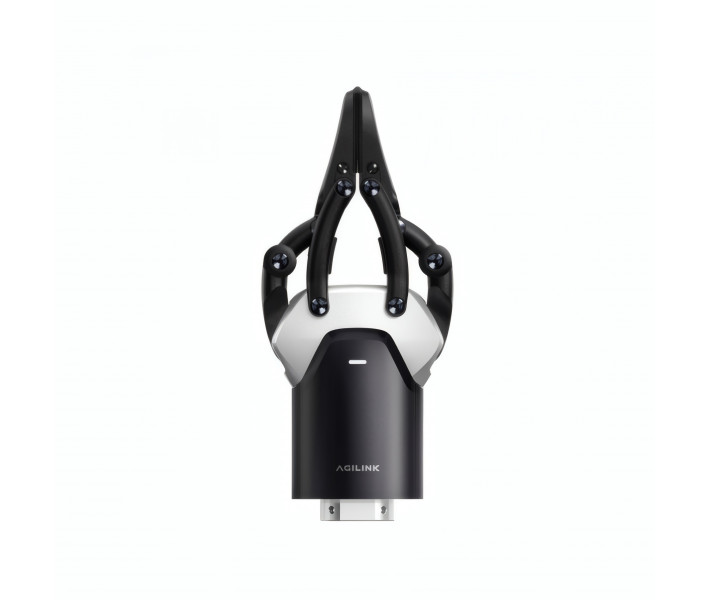
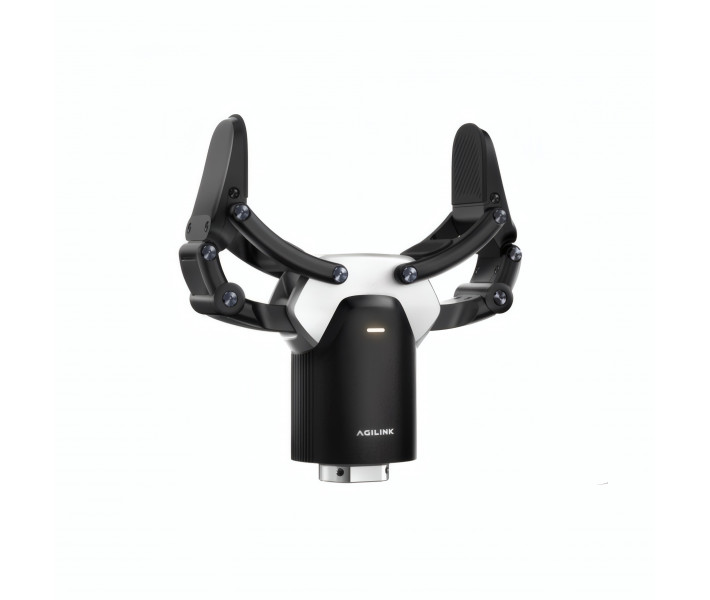
AgiBot OmniPicker 3 robotic gripper — an industrial end effector for automated sorting and handling of diverse objects. The device combines a high payload capacity with ultra-sensitive tactile surface control. The built-in sensor instantly registers the slightest changes in contact load. This ensures secure holding of both rigid components and delicate parts.
Key features and benefits
- Maximum force: 140 N — Allows heavy objects to be gripped securely, with no risk of shifting during sharp acceleration.
- Payload: 5 kg — Ensures stable transfer of medium-sized components in high-speed production cycles.
- Tactile sensitivity: 0.1 N — Prevents excessive pressure on fragile and deformable materials during gripping.
- Repeatability: ±0.1 mm — Guarantees stable positioning of products without accumulating errors on automated lines.
- High reliability: the mechanism withstands over 1,000,000 operating cycles without any degradation in kinematic performance.
- Industrial interfaces: support for the CAN FD and RS485 protocols simplifies connection to modern controllers.
- Data collection for AI: direct compatibility with the Dex-UMI platform optimises neural network training through demonstrations.
Functional capabilities of AgiBot OmniPicker 3
This end effector is designed for dynamic handling of a wide range of products in modern production facilities. Gripping reliability is based on an optimal balance between clamping force and the kinematic stability of the linkages.
The equipment integrates effectively into robotic cells for complex sorting and logistics distribution operations.
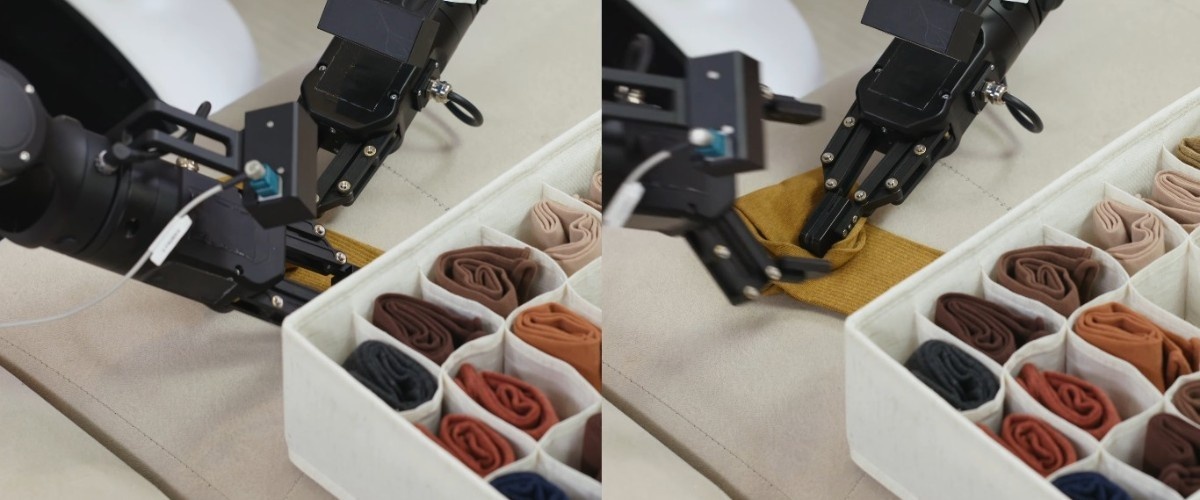
Kinematic parameters and force
The maximum clamping force reaches 140 N, which allows it to handle parts weighing up to 5 kg. The working opening of the mechanism is 110 ± 5 mm, for convenient gripping of objects of different shapes. The high repeatability of ±0.1 mm eliminates positioning errors during monotonous transfer operations. The service life of the design exceeds 1,000,000 cycles with no loss of its original characteristics.
Tactile feedback
The built-in one-dimensional sensor can detect changes in mechanical pressure with a resolution of 0.1 N. The sensor detects the moment of first contact with a surface well before the full rated force is applied. The control unit adjusts the pressure in real time depending on the resistance of the material. This eliminates the risk of cracking thin-walled housings or deforming fragile electronic components.
Adaptive control makes it possible to safely handle objects of variable geometry without manually readjusting the mechanical stops.
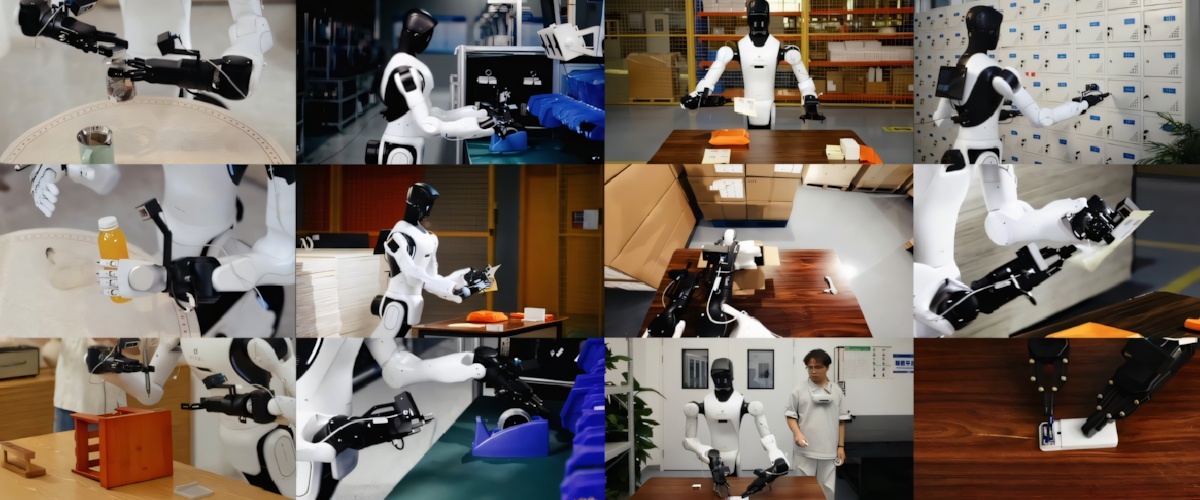
Telemetry and machine learning
The device serves as a hardware module for collecting physical parameters for artificial intelligence systems and teleoperation control. The effector transmits precise data on angular positions, linear speeds and the resulting contact stresses. Full integration with the Dex-UMI ecosystem makes it possible to quickly turn manual demonstrations into training datasets. The calculation of motion trajectories and the execution of complex algorithms are handled by an external industrial computer.
The video clearly demonstrates the process of robotic object manipulation and real-time telemetry data collection.
Industrial communication interfaces
The CAN FD and RS485 digital communication standards are used for fast data exchange. These buses provide a high command transmission speed and resistance to industrial electromagnetic interference. The interfaces are compatible with most modern motion controllers and on-board robot systems.
Below is a demonstration of the effector's kinematics during high-speed manipulation of various objects.
Applications
- Assembly lines: precise positioning of subassemblies and delicate mounting of electronic units on articulated manipulators.
- Industrial sorting: high-speed transfer and placement of parts on conveyor lines of varying intensity.
- Intralogistics: handling parcels, boxes and tools as part of mobile transport carts.
- Artificial intelligence training: building sensor databases for autonomous control through demonstration platforms.
- Handling delicate materials: packing thin-walled packaging, polymers and glass without any risk of breakage.
Compatible platforms and mechanical mounting
The effector is designed to be mounted on the wrist of industrial articulated robots, humanoid manipulators and mobile platforms. The rigid mechanical interface eliminates backlash during dynamic acceleration. Connection requires suitable power supplies and support for CAN FD or RS485 buses.
Technical specifications
Mechanical parameters
| Parameter | Value |
| Maximum force | 140 N |
| Payload | 5 kg |
| Maximum stroke | 110 ± 5 mm |
Accuracy and sensing
| Parameter | Value |
| Positioning repeatability | ±0.1 mm |
| Tactile sensor type | 1D |
| Force sensor resolution | 0.1 N |
Interfaces and dimensions and weight
| Parameter | Value |
| Communication buses | CAN FD / RS485 |
| Telemetry compatibility | UMI / Dex-UMI |
| Net weight | 0.780 kg |
Why buy the AgiBot OmniPicker 3 from EXPERT3D?
EXPERT3D has been supplying advanced robotic equipment and components since 2012. Our engineers provide expert consultations on mechanical mounting compatibility and communication bus configuration. We deliver throughout Spain and the EU countries. Customers receive qualified technical support and practical assistance during commissioning. We provide an official warranty and reliable service for every device.